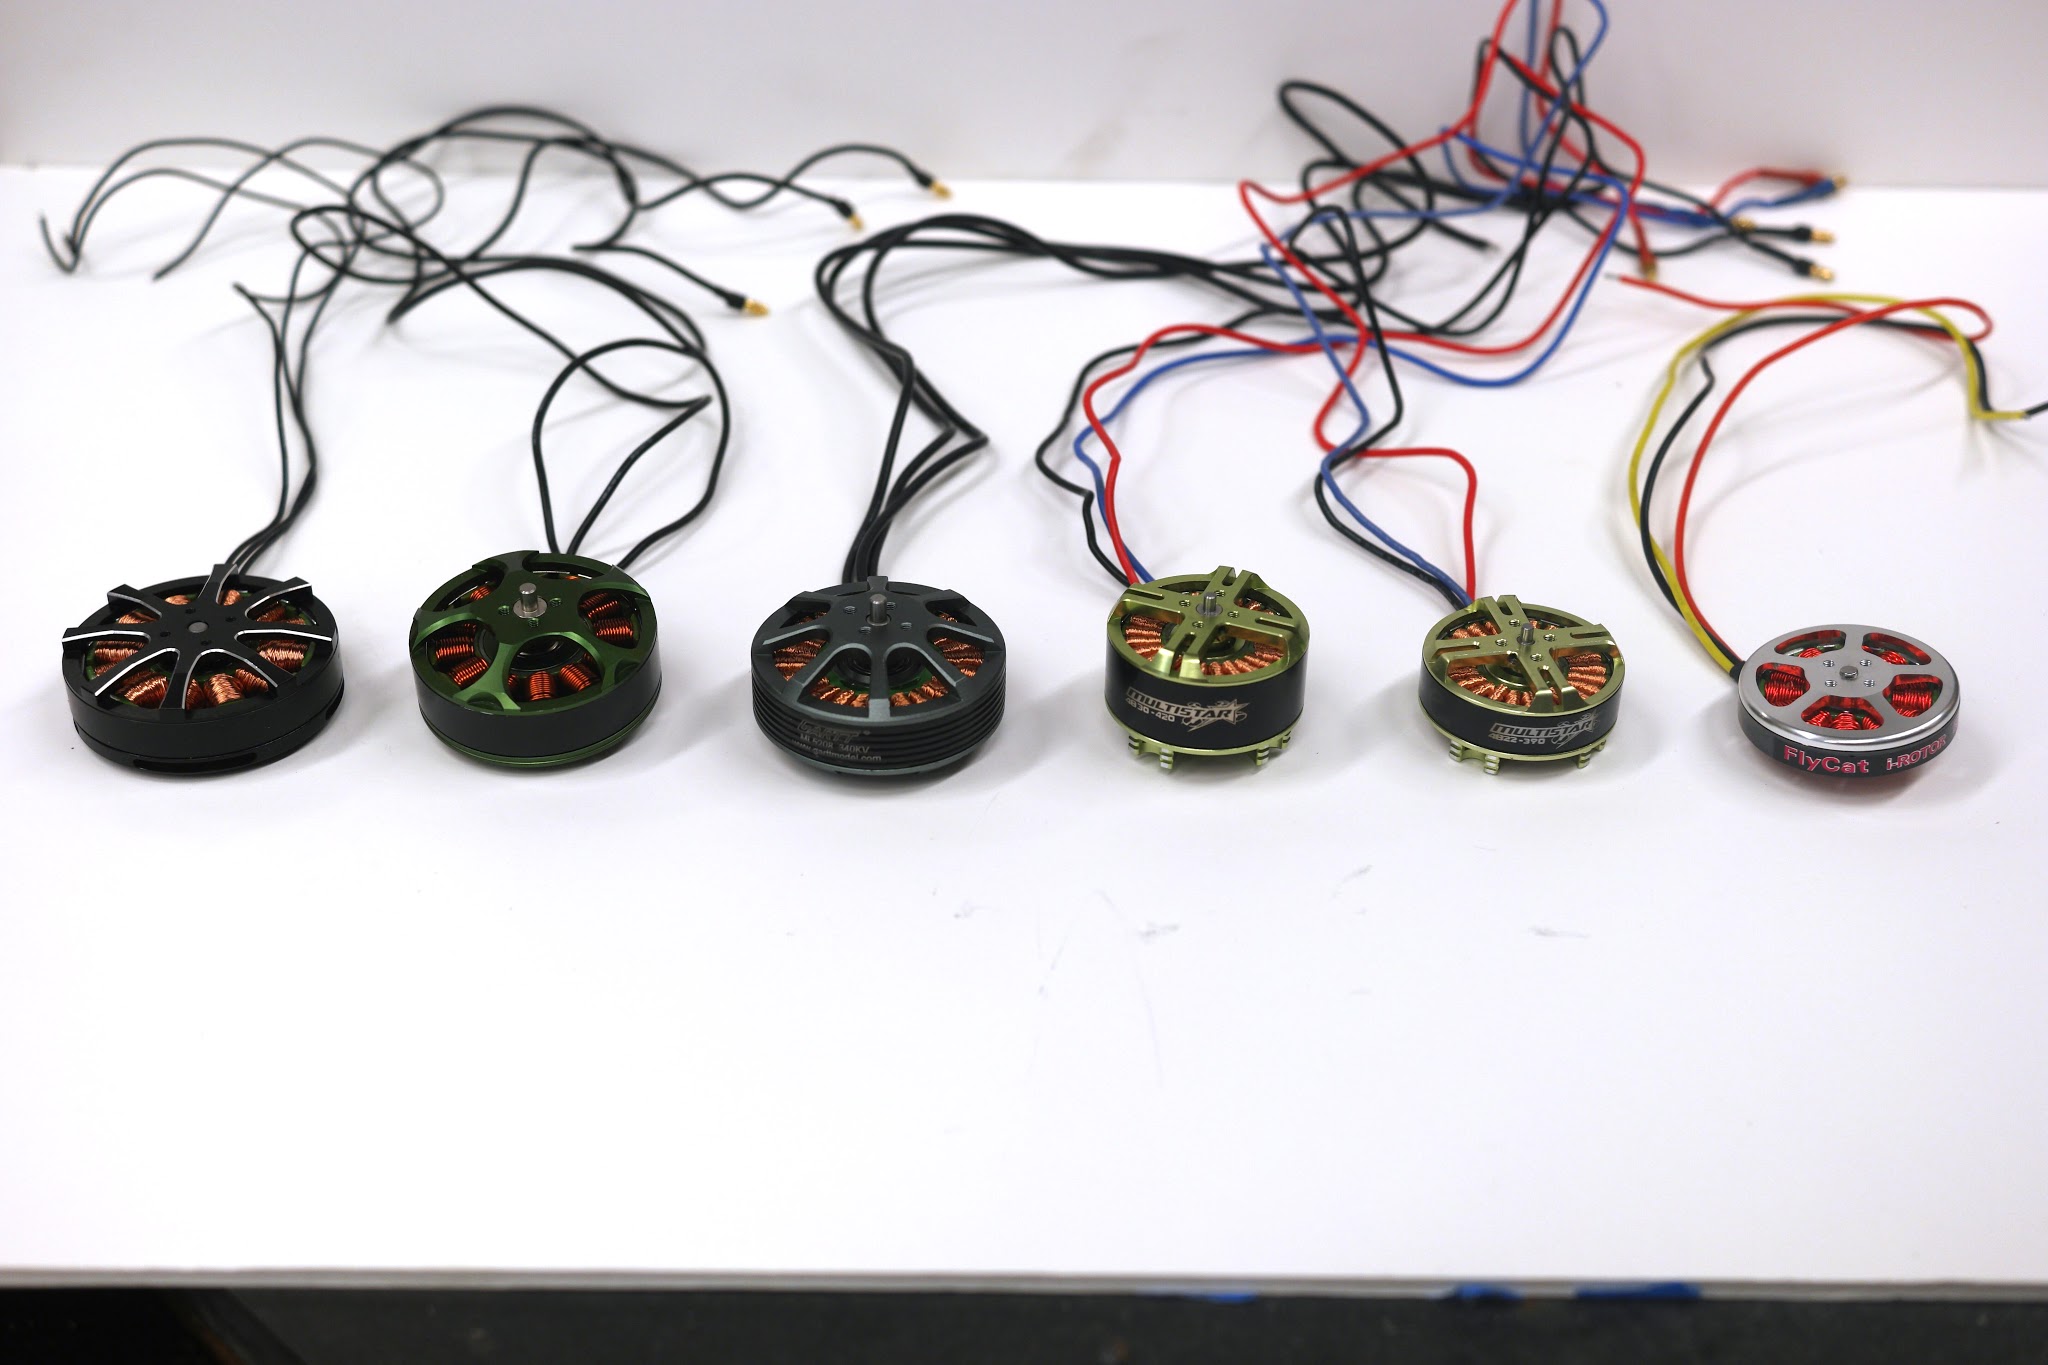
Motor Characterization for Small Running Robots (2016)
The article explains how to measure and model motor behavior for small running robots, covering torque‑speed curves, efficiency, and back‑EMF effects. It outlines an experimental setup for data collection and a calibration routine that can be automated. Findings indicate that accurate motor characterization can cut energy use by up to 15% and enhance gait stability, aiding designers in selecting suitable motors.